Uber ATG
Machine learning and motion planning for self-driving cars, 2016–2019.
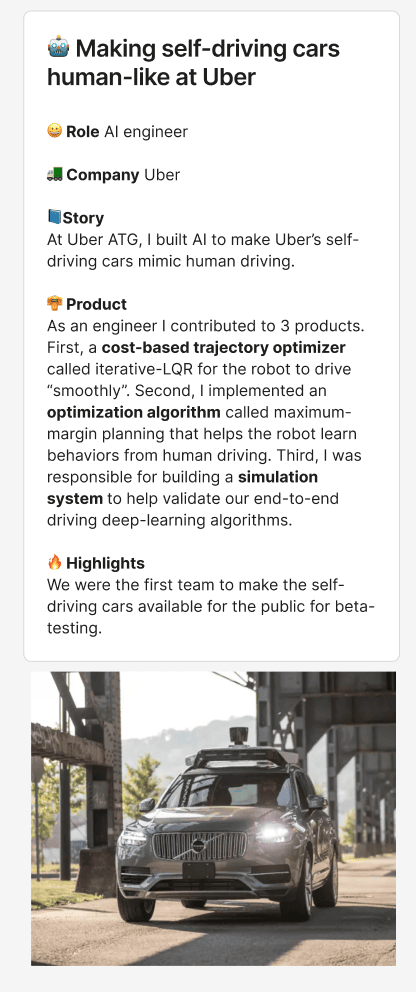
From 2016 to 2019 Andy was a machine learning engineer at Uber ATG, Uber’s self-driving research group. The 2020 essay says the work was on two teams:
- Motion planning, including iLQR trajectory optimization. The old about page also lists C++, trajectory optimization, and inverse reinforcement learning.
- Deep learning, including simulation used to check end-to-end driving models. The old about page lists Python and simulation for deep learning.
The essay describes applying in the summer of 2016 by pitching a one-year internship that was not an official opening, to the head of ML, instead of a full-time job. It also argues that the program scaled a large fleet in Pittsburgh, Phoenix, and San Francisco before the system could handle urban driving.
Notes from that period: Linear quadratic regulator , Differential dynamic programming , and Software design for machine learning . The longer reflection is Making self-driving cars human-like at Uber .
TODO(andy): The old site linked https://www.uber.com/info/atg/ . This page links to https://www.uber.com/ because that ATG path may be gone. Say if you want a different URL. Also confirm the job titles: the old about page splits “Machine Learning Engineer” and a later “Motion Planning Engineer”; the 2020 essay uses “machine learning engineer” for both teams.